Within Hand Manipulation using RL
Model-free reinforcement learning approach for planning within-hand manipulation tasks in robotic systems with multiple DOF and contact points.
Within Hand Manipulation (WIHM) is seen as a good skill in Robotic Manipulation tasks which reduces manipulation complexity in scenarios where an object needs to be re-oriented or re-positioned to perform a given task. The WIHM system involves multiple Degrees of Freedom, multiple points of contact and varying friction forces. This makes the kinematic and dynamic modeling of the system a complex task.
Inaccurate mathematical models will not suffice for accurately planning a trajectory using conventional control systems. Hence, this project explores a model-free approach for planning of WIHM tasks using Reinforcement Learning Techniques.
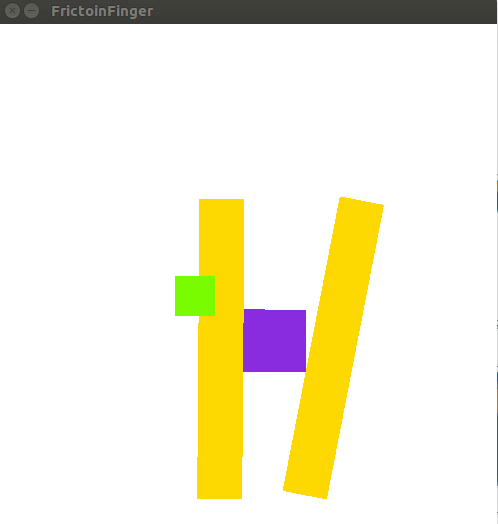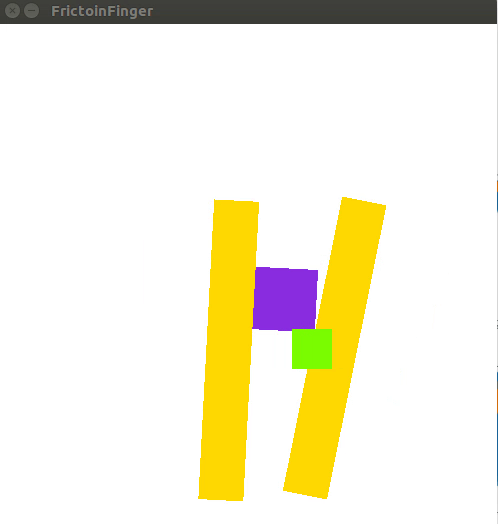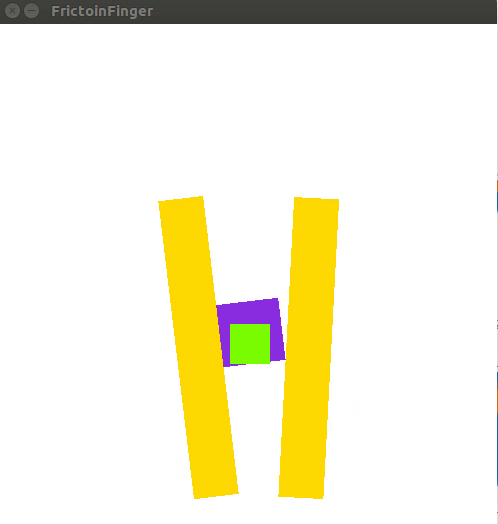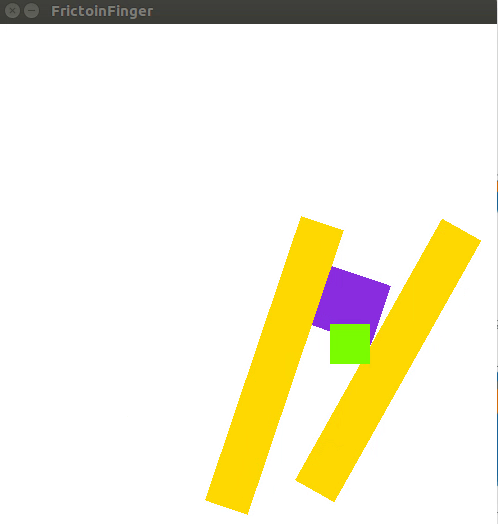
This work was carried out as a Masters Research under Dr. Berk Calli and Dr. Jing Xiao at Worcester Polytechnic Institute (WPI).
Tags: Motion Planning · Deep Reinforcement Learning · Deep Learning · Robotic Manipulation