Chinmay Burgul
Robotics Software Engineer · SLAM · State Estimation

cmburgul@gmail.com
Newark, DE
I am a roboticist, specializing in State Estimation, Localization and SLAM. I currently work as SLAM Engineer at Exyn Technologies, where I develop robust perception, localization, and mapping algorithms for autonomous robots operating in challenging environments.
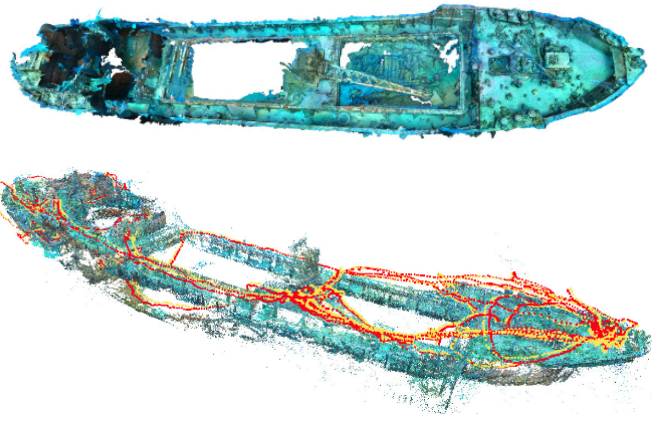
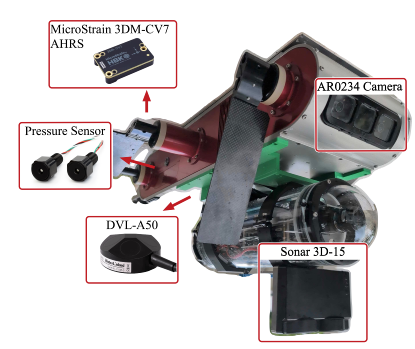
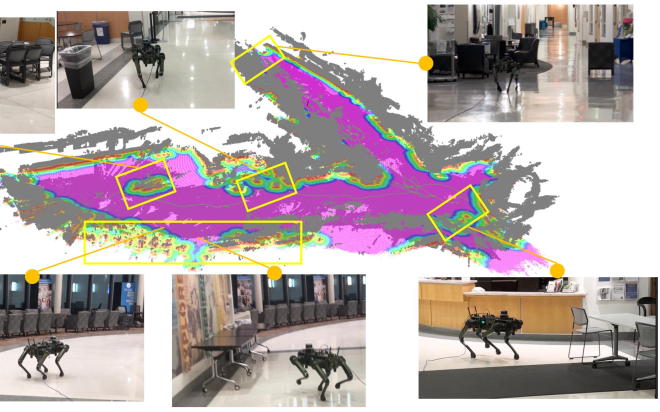
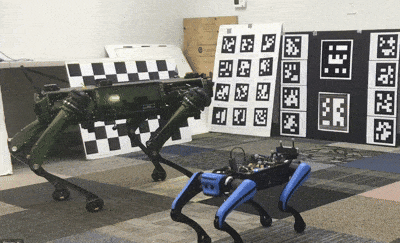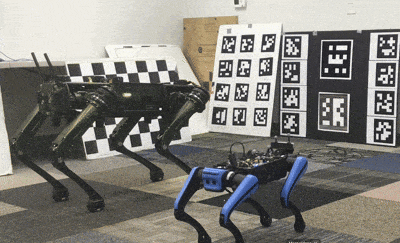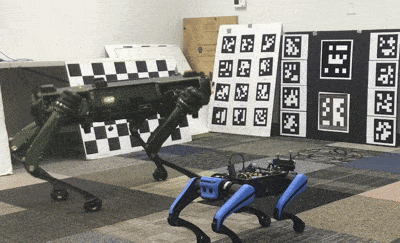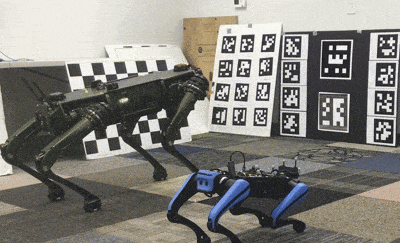
During my graduate studies at the University of Delaware, my research focused on visual-inertial odometry, 3D LiDAR- and sonar-inertial odometry, and multi-sensor fusion for autonomous systems. My work has included LiDAR- and sonar-inertial SLAM, visual-inertial odometry, and extrinsic calibration across heterogeneous sensor suites, including DVLs, pressure sensors, depth cameras, and legged-robot kinematics.
A central theme of my work is bridging algorithmic rigor with real-world deployment. I have developed and validated state-estimation and SLAM systems for underwater and legged robotic platforms, translating research concepts into robust algorithms and validating them through experimental evaluation and field deployment.
Previously, I earned my M.Sc. in Robotics Engineering at Worcester Polytechnic Institute (WPI), where I researched deep reinforcement learning for within-hand robotic manipulation.
Research Interests
- Multi-Sensor Fusion & Tightly-Coupled State Estimation
- Visual-Inertial Odometry, LiDAR-Inertial Odometry, 3D Sonar Odometry and SLAM
- Sensor Calibration
- Filtering and Non-Linear Optimization Theory
- Robotics Perception & Dense Mapping