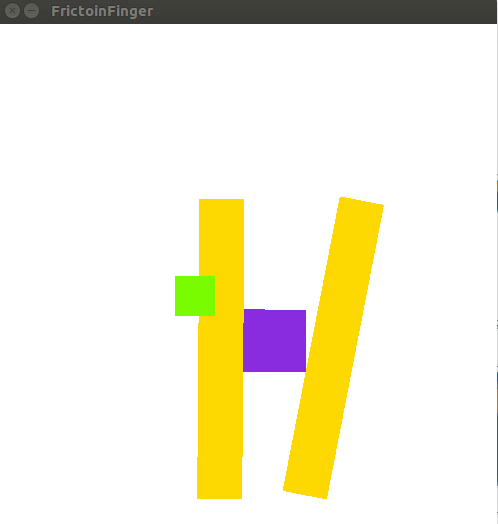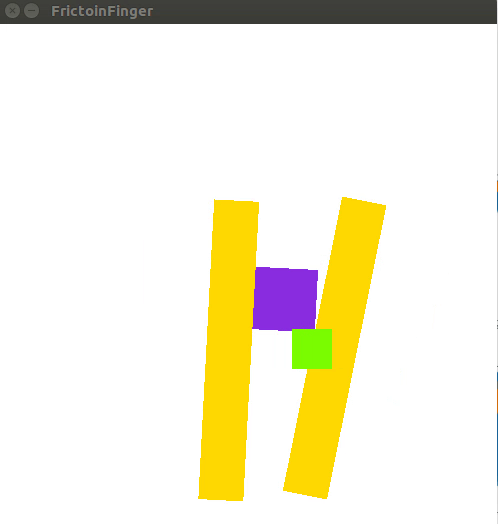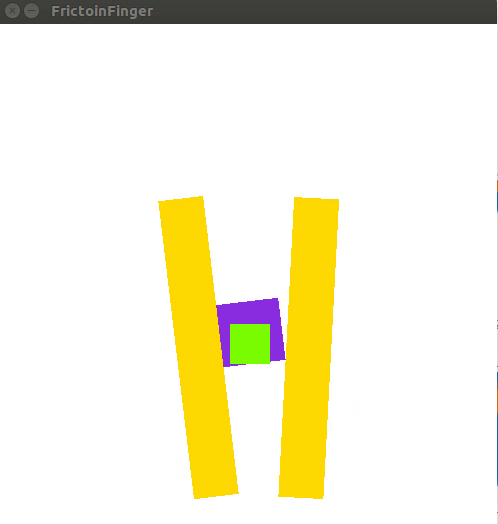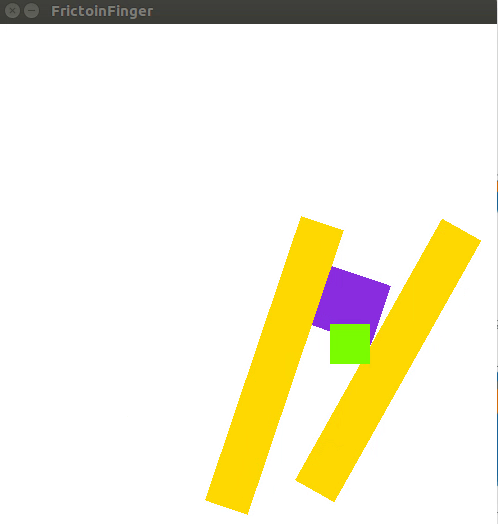
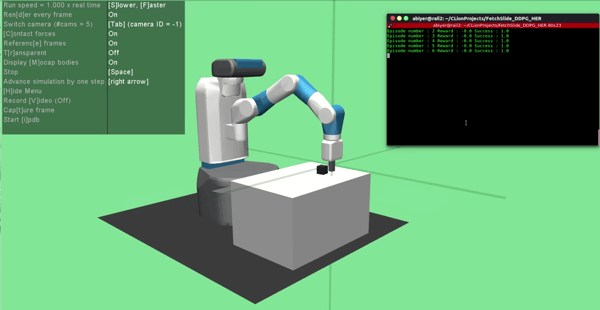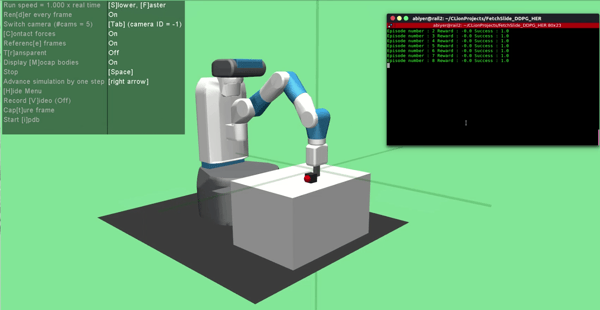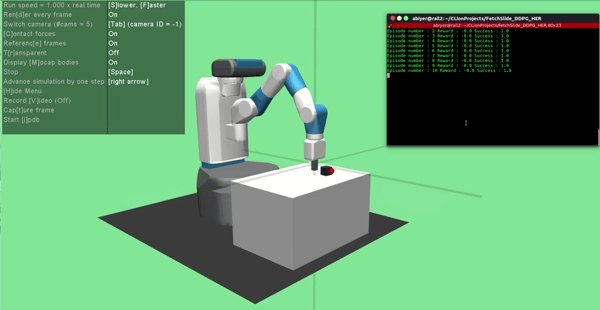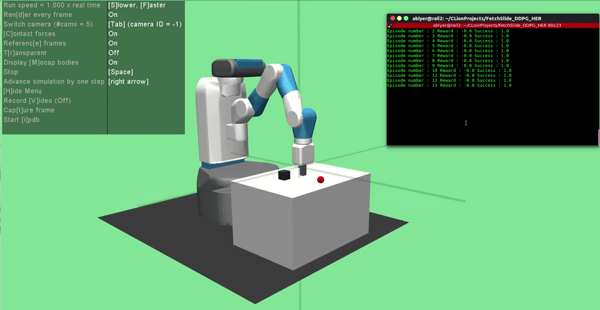
research Within Hand Manipulation using RL Model-free reinforcement learning approach for planning within-hand manipulation tasks in robotic systems with multiple DOF and contact points. Multi-Goal RL for Legged Robot Footstep Planning Iterative optimization method using multi-goal reinforcement learning for real-time dynamic footstep planning over a receding horizon for legged robots.