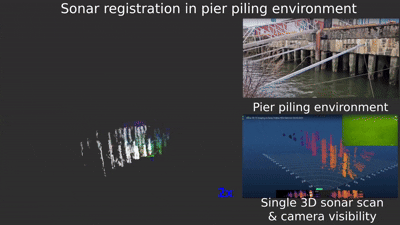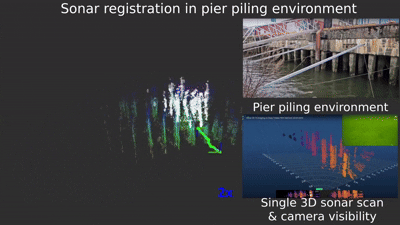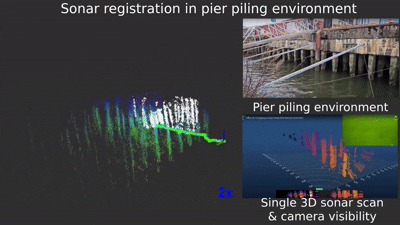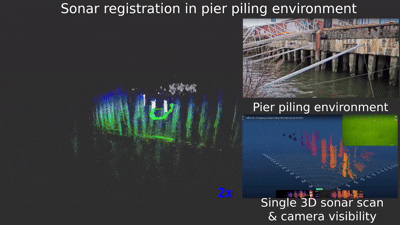
@inproceedings{burgul2026icra,author={Burgul, Chinmay and Huang, Yewei and Chatzispyrou, Michalis and Rekleitis, Ioannis and {Quattrini Li}, Alberto and Xanthidis, Marios},booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},title={Underwater Dense Mapping with the First Compact 3D Sonar},year={2026},}
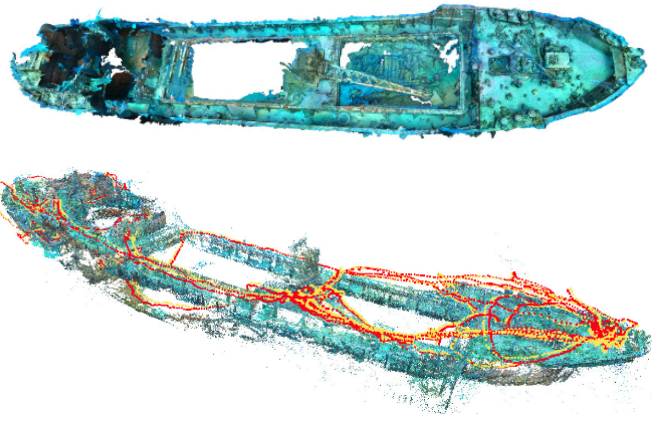
Mapping Pamir: Multi-Session Visual/Inertial SLAM and 3D Reconstruction of an Underwater Shipwreck
Michalis Chatzispyrou, Luke Horgan, Hyunkil Hwang, and 7 more authors
In 2026 IEEE International Conference on Robotics and Automation (ICRA), 2026
@inproceedings{Chatzispyrou2025PamirArxiv_,title={Mapping Pamir: Multi-Session Visual/Inertial SLAM and 3D Reconstruction of an Underwater Shipwreck},author={Chatzispyrou, Michalis and Horgan, Luke and Hwang, Hyunkil and Sathishchandra, Harish and Burgul, Chinmay and Roznere, Monika and Quattrini Li, Alberto and Mordohai, Philippos and Rekleitis, Ioannis and Xanthidis, Marios},booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},year={2026},}
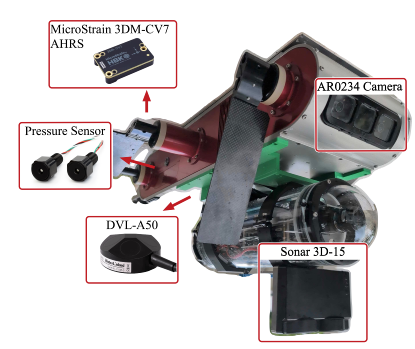
SVIn+: Multi-Modal Framework for Robust Underwater State Estimation using 3D Sonar, Visual-Inertial, Water-Pressure, and DVL
Chinmay Burgul, Xiaoming Zhao, Yewei Huang, and 4 more authors
In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
@inproceedings{Burgul2026Svin+,title={SVIn+: Multi-Modal Framework for Robust Underwater State Estimation using 3D Sonar, Visual-Inertial, Water-Pressure, and DVL},author={Burgul, Chinmay and Zhao, Xiaoming and Huang, Yewei and Chatzispyrou, Michalis and Xanthidis, Marios and Rekleitis, Ioannis and {Quattrini Li}, Alberto},booktitle={2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},}
2025
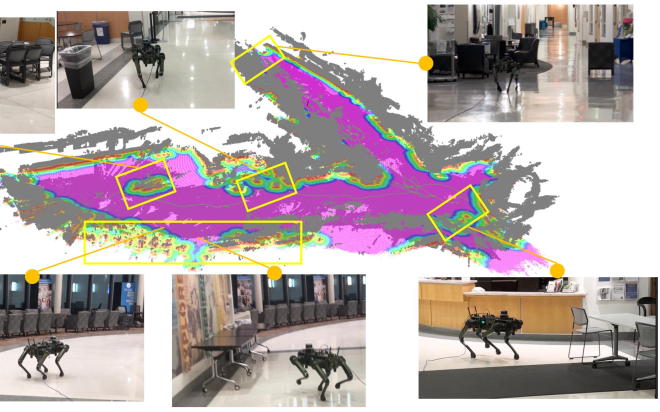
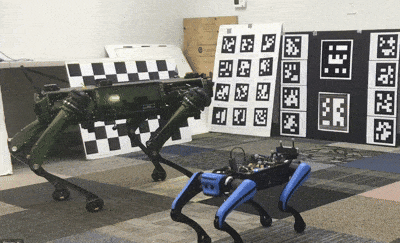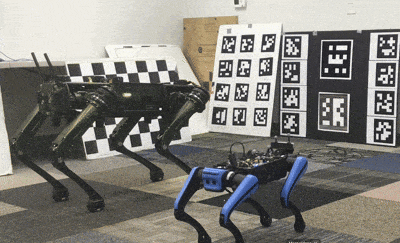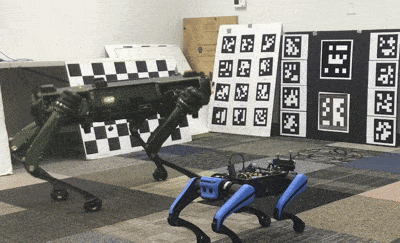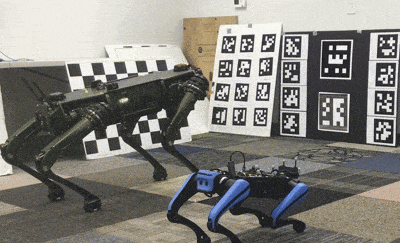
Efficient Multimodal Quadrupedal Autonomy: Algorithm, System and Application
Abhijeet Kulkarni*, Chinmay Burgul*, Yuze Du, and 1 more author
@inproceedings{burgul2024legged,author={Burgul, Chinmay and Lee, Woosik and Geneva, Patrick and Huang, Guoquan},booktitle={2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},title={Online Determination of Legged Kinematics},year={2024},pages={9043--9049},doi={10.1109/IROS58592.2024.10801595},}